
Measurement
Measurement functions return Result<number>. Null shapes and other inputs that prevent measurement surface as BrepError rather than throwing. For valid inputs, unwrap() extracts the number; in production code prefer isOk() / match(). You ask "what is the volume of this thing?" and you get a Result. This chapter is short because the API is small.
The four core measurements
import {
  box,
  cylinder,
  sketchCircle,
  edgeFinder,
  measureVolume,
  measureArea,
  measureLength,
  unwrap,
} from 'brepjs/quick';

const b = box(10, 10, 10);
const cyl = cylinder(5, 20);

console.log('Box volume:', unwrap(measureVolume(b))); // 1000
console.log('Cylinder volume:', unwrap(measureVolume(cyl)).toFixed(3)); // 1570.796
console.log('Box area:', unwrap(measureArea(b))); // 600
console.log('Cylinder area:', unwrap(measureArea(cyl)).toFixed(3)); // 785.398

// Edge length
const cylinder2 = sketchCircle(10).extrude(20);
const circularEdge = edgeFinder().ofCurveType('CIRCLE').findAll(cylinder2)[0];
if (circularEdge) {
  console.log('Edge length:', unwrap(measureLength(circularEdge)).toFixed(3)); // 62.832
}

export default cylinder2;| Function | Argument | Returns |
|---|---|---|
measureVolume(shape) | Shape3D | Result<number>: total volume in cubic units |
measureArea(shape) | Shape3D or Face | Result<number>: total surface area in square units |
measureLength(edge) | Edge or Wire | Result<number>: length along the curve |
These are the workhorses. The fluent wrapper exposes them as methods: shape(s).volume(), shape(s).area().
Bounding box
The axis-aligned bounding box of a shape:
import { box, getBounds } from 'brepjs/quick';

const b = box(30, 20, 10, { at: [5, 5, 5] }); // `at` is the box centre
const bbox = getBounds(b);
console.log('Min:', [bbox.xMin, bbox.yMin, bbox.zMin]); // [-10, -5, 0]
console.log('Max:', [bbox.xMax, bbox.yMax, bbox.zMax]); // [20, 15, 10]
console.log('Size:', [bbox.xMax - bbox.xMin, bbox.yMax - bbox.yMin, bbox.zMax - bbox.zMin]); // [30, 20, 10]

export default b;
getBounds returns { xMin, xMax, yMin, yMax, zMin, zMax }. The bounding box is in world coordinates and updates after every transform. Useful for layout and packing.
Centre of mass
import { box, cylinder, fuse, measureVolumeProps, unwrap } from 'brepjs/quick';

const compound = unwrap(fuse(box(20, 20, 20), cylinder(5, 30, { at: [10, 10, 0] })));
const com = unwrap(measureVolumeProps(compound)).centerOfMass;
console.log(
  'Centre of mass:',
  com.map((c) => c.toFixed(3))
);

export default compound;
Returns [x, y, z]. Computed via the kernel's mass-property analysis assuming uniform density.
Distance and projection
The closest point between two shapes:
import { box, sphere, measureDistanceProps, unwrap } from 'brepjs/quick';

const a = box(10, 10, 10);
const b = sphere(3, { at: [50, 0, 0] });

const result = unwrap(measureDistanceProps(a, b));
console.log('Distance:', result.distance.toFixed(3)); // 37
console.log('Closest on A:', result.point1);
console.log('Closest on B:', result.point2);
Returns { distance, point1, point2 }. The points are the closest pair. On the default occt-wasm kernel they are sampled from a tessellation, so they are approximate while distance stays exact. measureDistance(a, b) returns just the number.
The distance is never negative: touching or overlapping shapes report 0. For overlap detection use checkInterference(a, b), whose hasInterference is true when the distance is within a tolerance.
Projecting a point onto a surface
import { sketchCircle, faceFinder, projectPointOnFace, unwrap } from 'brepjs/quick';

const cyl = sketchCircle(10).extrude(20);
const sideFace = faceFinder().ofSurfaceType('CYLINDRE').findAll(cyl)[0];
if (sideFace) {
  const proj = unwrap(projectPointOnFace(sideFace, [15, 0, 5]));
  console.log('Projected to:', proj.point); // [10, 0, 5]
  console.log('Distance:', proj.distance); // 5
}
Useful for placing features (logos, fasteners) at a specific position on a curved surface.
Surface curvature
import { sketchCircle, faceFinder, measureCurvatureAtMid, unwrap } from 'brepjs/quick';

const cyl = sketchCircle(10).extrude(20);
const side = faceFinder().ofSurfaceType('CYLINDRE').findAll(cyl)[0];
if (side) {
  const c = unwrap(measureCurvatureAtMid(side)); // centre of the face's UV range
  console.log('Min curvature:', c.minCurvature); // 0 (along axis)
  console.log('Max curvature:', c.maxCurvature); // 0.1 = 1/r (around)
  console.log('Gaussian:', c.gaussian); // 0
  console.log('Mean:', c.mean); // 0.05
}
Returns principal curvatures (with their directions), Gaussian, and mean. measureCurvatureAt(face, u, v) evaluates at explicit parameters in the face's own UV domain. Useful for detecting flat regions (curvature ~0) or sharp regions (high max).
Counts
import { box, vertexFinder, edgeFinder, faceFinder } from 'brepjs/quick';

const b = box(20, 20, 20);
console.log({
  vertices: vertexFinder().findAll(b).length, // 8
  edges: edgeFinder().findAll(b).length, // 12
  faces: faceFinder().findAll(b).length, // 6
});
For a quick "how complex is this shape" check, count entities at each level. A simple part has tens of edges; a heavily-filleted assembly has thousands.
Performance notes
- Volume and area are cheap (kernel mass-properties query).
- Distance between two shapes can be expensive, proportional to face counts. For repeated distance queries, build a spatial index (
flatbushis included as a dependency) over your shapes' bounding boxes. - Curvature queries are constant-time at a single parameter, but evaluating a dense grid of points is naive; there's no built-in batched API.
Common patterns
Volume check after a boolean
import { box, cylinder, cut, measureVolume, isOk, unwrap } from 'brepjs/quick';

const block = box(20, 20, 20);
const hole = cylinder(5, 25);
const result = cut(block, hole);

if (isOk(result)) {
  const before = unwrap(measureVolume(block));
  const after = unwrap(measureVolume(result.value));
  const removed = before - after;
  console.log(`Cut removed ${removed.toFixed(2)} mm³`);
}

export default isOk(result) ? result.value : block;
Sanity-check that booleans actually changed the volume by the expected amount.
Tightest fit packing
For a layout tool, you need bounding boxes:
import { box, getBounds } from 'brepjs/quick';

const parts = [box(10, 20, 5), box(15, 10, 5), box(25, 15, 5)];
const bboxes = parts.map((p) => getBounds(p));
const totalWidth = bboxes.reduce((sum, bb) => sum + (bb.xMax - bb.xMin), 0);
console.log('Total width if linear-packed:', totalWidth);
Mass with non-unit density
The kernel computes everything assuming density 1. Multiply at the end:
import { box, measureVolume, unwrap } from 'brepjs/quick';

const part = box(30, 20, 10);
const volumeMm3 = unwrap(measureVolume(part));
const volumeCm3 = volumeMm3 / 1000;
const aluminiumDensity = 2.7; // g/cm³
const massGrams = volumeCm3 * aluminiumDensity;
console.log(`Mass: ${massGrams.toFixed(2)} g`);
Examples
These playground examples print a quantity that the kernel measures: a mass, a centre of mass, a clearance or an area.
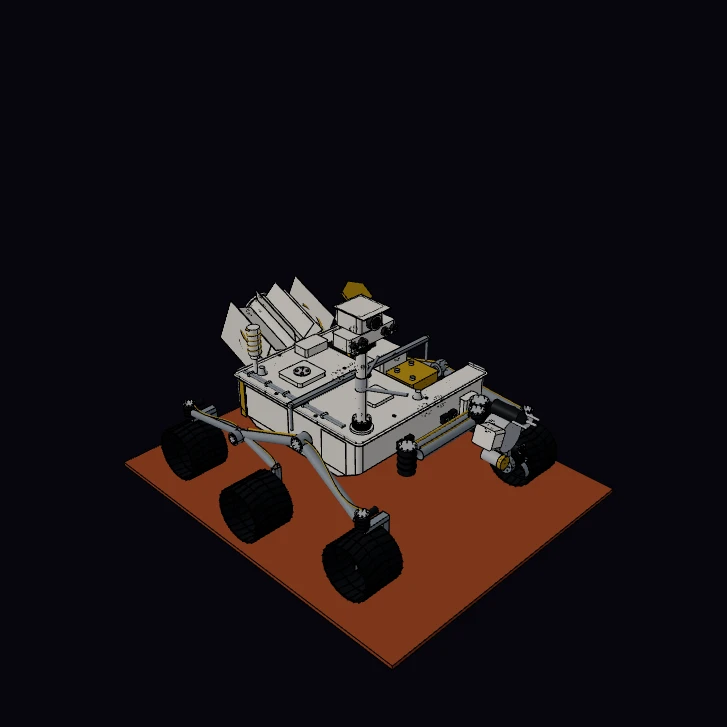 Mars RoverA six-wheel planetary rover of the 1-tonne class with a rocker-bogie suspension, in cutaway. The wheel size, the corner wheel positions, the deck height, the ground clearance, the mast height and the arm length are published figures. The kernel measures the volume of each part, and the example turns the volumes into a mass budget of 899 kg and a centre of mass. The arm parameter moves the arm, and the centre of mass moves with it. The screws are hexagon head screws M5, M6 and M8 to ISO 4017, each in a clearance hole and a tapped hole. The link lengths, the body layout and the equipment inside the body are a display model.
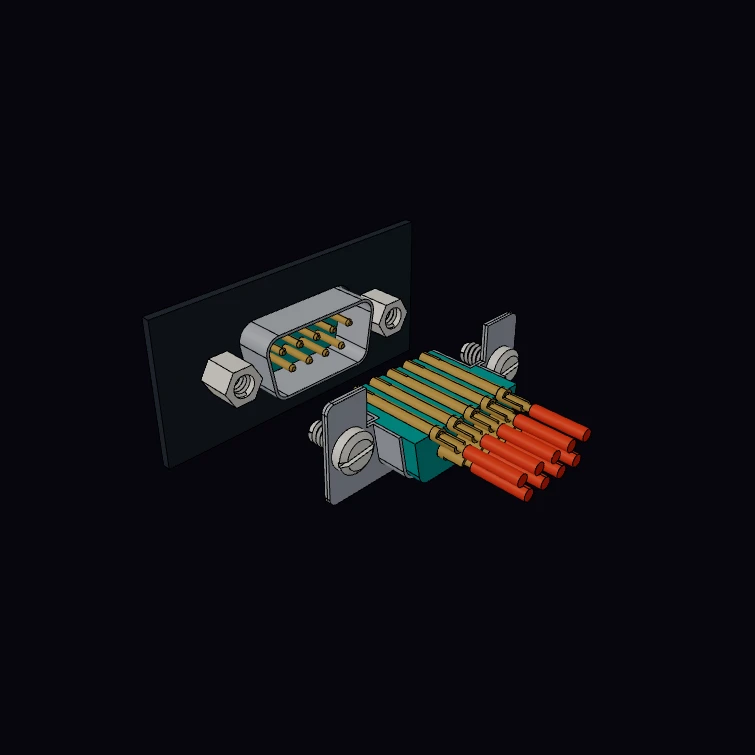 DE-9 D-Sub Connector PairA DE-9 pair before it mates: a panel plug with two jackposts, and a solder-cup socket with jackscrews and wires, cut open at its upper contact row. The flange, the two shell sizes, the 2.77 by 2.84 mm contact grid and the 4-40 UNC thread are published figures. The jackscrews, the jackposts and their nuts have helical threads, and each jackscrew turns one turn for each pitch as the pair mates. The kernel measures the clearance between the mated shells. The insulators, the contacts, the hardware and the panel are a display model.
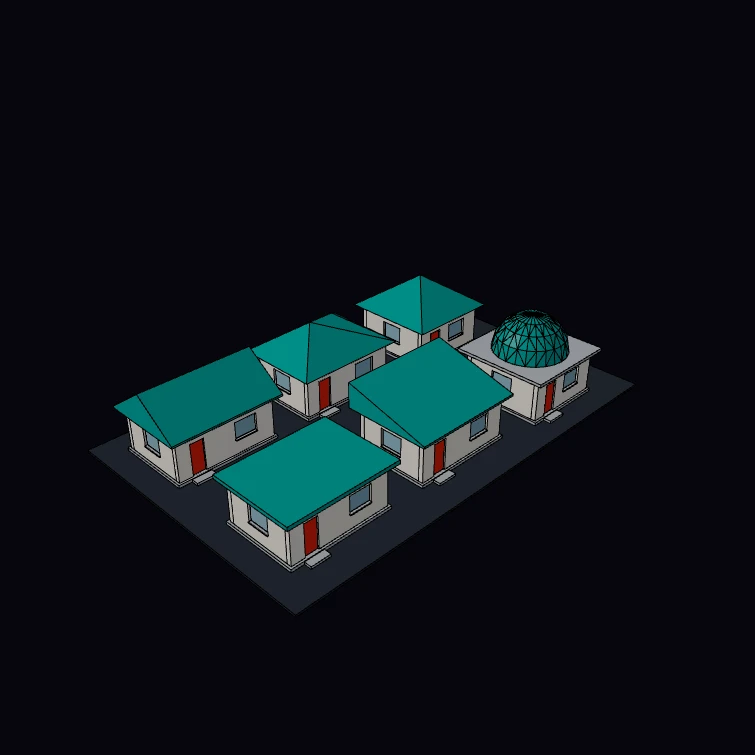 Roof GallerySix roofs of the brepjs-bim roof builder on six small pavilions: gable, hip, pyramid, flat, shed and dome. Each one is a real IfcRoof solid that one addRoof call shapes from its type and its pitch, and the IFC export writes each body. The 35 degree pitch is the published minimum for clay plain tiles. The kernel measures the tiled area of each roof: the gable and the hip have the same area. The pavilions are a display model.
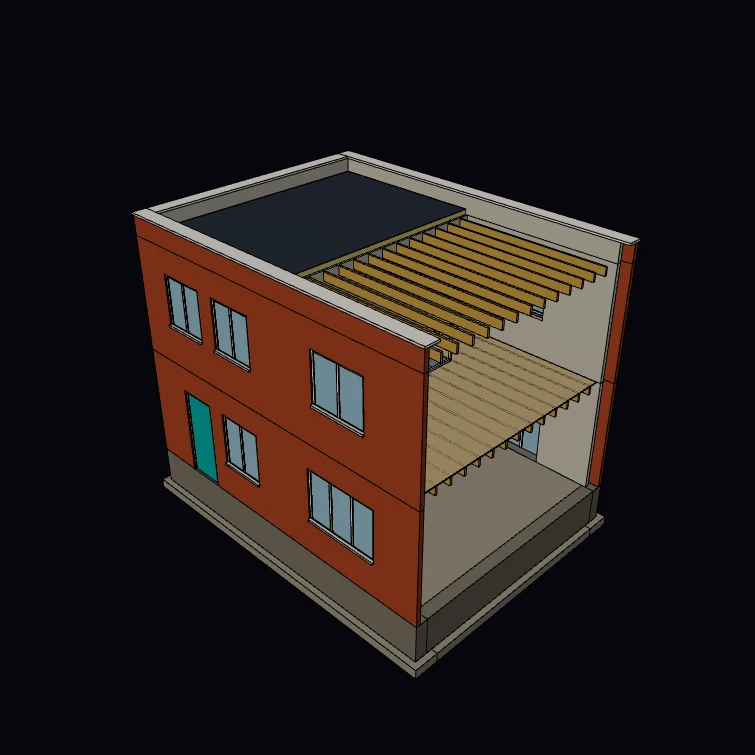 Quantity TakeoffA quantity schedule of a brick and block house shell, computed from the model: the kernel measures the net volume of each element after the openings are cut, and the schedule groups the volumes by category and material. The brick and block sizes, the joint and the stair limits are published figures, and the console compares the brick and block counts with the guide figures of 60 and 10 for each square metre. The plan, the openings, the joists and the roof are a display model. The Files button saves the schedule as CSV.
Next steps
- Finders & Queries: selecting specific entities to measure
- Import & Export: measuring shapes you imported from STEP
- The Topology Hierarchy: what each shape kind contributes to area / volume