
Mars Rover
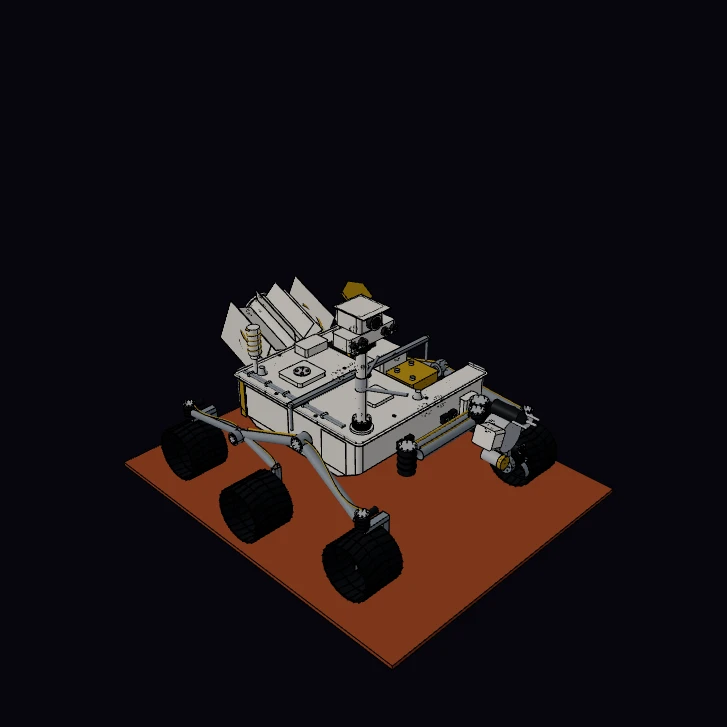
A six-wheel planetary rover of the 1-tonne class with a rocker-bogie suspension, in cutaway. The wheel size, the corner wheel positions, the deck height, the ground clearance, the mast height and the arm length are published figures. The kernel measures the volume of each part, and the example turns the volumes into a mass budget of 899 kg and a centre of mass. The arm parameter moves the arm, and the centre of mass moves with it. The screws are hexagon head screws M5, M6 and M8 to ISO 4017, each in a clearance hole and a tapped hole. The link lengths, the body layout and the equipment inside the body are a display model.
Code
This is the full program. The playground runs it in your browser without a change.
import {
  box,
  circle,
  compound,
  cone,
  cutAll,
  cylinder,
  edgeFinder,
  extrude,
  face,
  fillet,
  fuseAll,
  getSolids,
  helix,
  interpolateCurve,
  line,
  measureVolumeProps,
  polygon,
  rotate,
  sweep,
  threePointArc,
  translate,
  unwrap,
  wire,
} from 'brepjs/quick';
import { color } from 'brepjs/playground';

// Six-wheel planetary rover of the 1-tonne class with a rocker-bogie suspension, in cutaway. The wheel size, the
// positions of the corner wheels, the deck height, the ground clearance, the mast height and the arm length are
// published figures. The kernel measures the volume of each part, and a density or a published mass turns it
// into a mass budget and a centre of mass. The link lengths, the body layout, the equipment
// inside the body and all small parts are a display model. Units are millimetres and kilograms. X is forward,
// Y is left, Z is up, and the origin is on the ground below the middle axle.
const DEG = Math.PI / 180;

type P2 = [number, number];
type P3 = [number, number, number];
type Shape = ReturnType<typeof cylinder>;
type Tone = 'white' | 'dark' | 'titanium' | 'metal' | 'gold' | 'accent';
type System = 'wheels' | 'suspension' | 'body' | 'equipment' | 'power' | 'arm' | 'mast' | 'antennas';
type Link = 'body' | 'rockerL' | 'rockerR' | 'bogieL' | 'bogieR';
interface Part {
  system: System;
  tone: Tone;
  link: Link;
  shape: Shape;
  kg: number;
  at: P3; // centre of mass
  skin?: boolean; // the cutaway opens this part
  joint?: 1 | 2 | 3; // the arm joint that the part turns with: 1 shoulder, 2 elbow, 3 wrist
}

// Kernel shapes live in WASM memory. Every shape goes through own(). freeing() runs a build and then frees them all.
const owned: { delete(): void }[] = [];
const own = <T extends { delete(): void }>(s: T): T => {
  owned.push(s);
  return s;
};
const freeing = <T,>(build: () => T): T => { try { return build(); } finally { owned.splice(0).forEach((s) => s.delete()); } }; // also when the build throws

// ---- published figures
const WHEEL = { radius: 250, width: 400, skin: 0.75, grousers: 24, grouserHeight: 7.5 };
const AXLE = { front: 1150, rear: -1110, cornerTrack: 2125, middleTrack: 2430 }; // the corner axles are 2,260 mm apart
const DECK = 1100; // top of the body
const CLEARANCE = 660; // under the body
const MAST_TOP = 2200;
const ARM_LENGTH = 2200; // from the shoulder to the centre of the turret
const TOTAL_KG = 899;
const PUBLISHED_KG = { power: 45, arm: 70, turret: 30 };
// kg per cubic millimetre. An instrument box is mostly electronics and air.
const DENSITY = { aluminium: 2.7e-6, titanium: 4.43e-6, instrument: 0.8e-6, cable: 2.2e-6 };
// Hexagon head screws (ISO 4017) with the coarse thread (ISO 724): width across flats, head height, clearance
// hole of the medium series (ISO 273) and tap drill (ISO 2306).
const SCREW = {
  M5: { pitch: 0.8, minor: 4.134, flats: 8, head: 3.5, clearance: 5.5, tapDrill: 4.2 },
  M6: { pitch: 1, minor: 4.917, flats: 10, head: 4, clearance: 6.6, tapDrill: 5 },
  M8: { pitch: 1.25, minor: 6.647, flats: 13, head: 5.3, clearance: 9, tapDrill: 6.8 },
};
type Size = keyof typeof SCREW;

// ---- display layout
const BODY = { x0: -720, x1: 850, half: 800 };
const PIVOT: P2 = [250, 880]; // rocker pivot on the body, as [x, z]
const BOGIE: P2 = [-480, 640]; // bogie pivot on the rocker
const PIVOT_Y = 880;
const BOGIE_Y = 940;
// The arm has three vertical joints. Each one is a point and an angle in degrees, for a reach from 0 (the
// arm folded across the front) to 1 (the arm straight out).
const SHOULDER: P3 = [BODY.x1 + 160, 520, 900];
const armJoints = (reach: number): [P2, number][] => [
  [[SHOULDER[0], SHOULDER[1]], 90 * reach],
  [[SHOULDER[0] + 65, SHOULDER[1] - 1000], -180 * reach],
  [[SHOULDER[0] + 130, SHOULDER[1] - 200], 90 * reach],
];
const OPENING = { x0: -560, x1: 640, y0: 140, z0: 705 }; // the cutaway takes the deck and the left wall over this range

const solidOf = (s: Shape, tools: Shape[]): Shape => own(unwrap(cutAll(s, tools))) as Shape;
const fused = (parts: Shape[]): Shape => own(unwrap(fuseAll(parts))) as Shape;
const group = (parts: Shape[]): Shape => own(compound(parts)) as Shape;
const rounded = (s: Shape, r: number): Shape => own(unwrap(fillet(s, edgeFinder().inDirection('Z').findAll(s), r))) as Shape;
const block = (x0: number, x1: number, y0: number, y1: number, z0: number, z1: number): Shape =>
  own(translate(own(box(x1 - x0, y1 - y0, z1 - z0)), [x0, y0, z0])) as Shape;
const along = (a: P3, b: P3, t: number, lift = 0): P3 => [a[0] + (b[0] - a[0]) * t, a[1] + (b[1] - a[1]) * t, a[2] + (b[2] - a[2]) * t + lift];
const rod = (a: P3, b: P3, r: number, bore = 0): Shape => {
  const axis: P3 = [b[0] - a[0], b[1] - a[1], b[2] - a[2]];
  const len = Math.hypot(...axis);
  const outer = own(cylinder(r, len, { at: a, axis }));
  if (bore === 0) return outer;
  const back: P3 = [a[0] - axis[0] / len, a[1] - axis[1] / len, a[2] - axis[2] / len];
  return solidOf(outer, [own(cylinder(bore, len + 2, { at: back, axis }))]);
};
// A box-section beam from a to b. With a wall, the beam is hollow.
const beam = (a: P3, b: P3, w: number, h: number, wall = 0): Shape => {
  const d: P3 = [b[0] - a[0], b[1] - a[1], b[2] - a[2]];
  const len = Math.hypot(...d);
  let s = own(translate(own(box(len, w, h)), [0, -w / 2, -h / 2])) as Shape;
  if (wall > 0) s = solidOf(s, [own(translate(own(box(len + 2, w - 2 * wall, h - 2 * wall)), [-1, wall - w / 2, wall - h / 2])) as Shape]);
  const pitched = own(rotate(s, -Math.atan2(d[2], Math.hypot(d[0], d[1])) / DEG, { axis: [0, 1, 0] }));
  return own(translate(own(rotate(pitched, Math.atan2(d[1], d[0]) / DEG)), a)) as Shape;
};
// A ring of hexagon head screws about the line through seat along n. The heads sit on the plane of seat and
// point along n. Each screw goes through a part of thickness grip into a tapped hole in the part under it.
// The threads are inside the holes and are not modelled: a shank is the root cylinder, in a hole of the tap
// drill size. clear and tap are the tools that cut the holes in the two parts.
type Ring = { screws: Shape; clear: Shape[]; tap: Shape[] };
type Bolted = (seat: P3, n: P3, radius: number, count: number, size: Size, grip: number, length: number) => Ring;
const fasteners = (): Bolted => {
  const made = new Map<string, Shape>();
  const screw = (size: Size, length: number): Shape => {
    const key = size + ' x ' + length;
    const { flats, head, minor } = SCREW[size];
    const c = flats / Math.sqrt(3);
    const hexagon = (): Shape => own(unwrap(extrude(own(unwrap(polygon(Array.from({ length: 6 }, (_, i): P3 => [c * Math.cos(i * 60 * DEG), c * Math.sin(i * 60 * DEG), 0])))), head))) as Shape;
    if (!made.has(key)) made.set(key, fused([hexagon(), own(cylinder(minor / 2, length, { at: [0, 0, -length] }))]));
    return made.get(key) as Shape;
  };
  return (seat, n, radius, count, size, grip, length) => {
    const flat = Math.hypot(n[0], n[1]);
    const u: P3 = flat < 0.4 ? [1, 0, 0] : [-n[1] / flat, n[0] / flat, 0];
    const v: P3 = [n[1] * u[2] - n[2] * u[1], n[2] * u[0] - n[0] * u[2], n[0] * u[1] - n[1] * u[0]];
    const turned = own(rotate(screw(size, length), Math.atan2(flat, n[2]) / DEG, { axis: flat < 1e-9 ? [1, 0, 0] : [-n[1], n[0], 0] })) as Shape;
    const spots = Array.from({ length: count }, (_, i) => {
      const t = (i * 2 * Math.PI) / count;
      return [0, 1, 2].map((k) => (seat[k] as number) + radius * (Math.cos(t) * (u[k] as number) + Math.sin(t) * (v[k] as number))) as P3;
    });
    const hole = (p: P3, d: number, from: number, to: number): Shape =>
      own(cylinder(d / 2, to - from, { at: [p[0] + n[0] * from, p[1] + n[1] * from, p[2] + n[2] * from], axis: n }));
    return {
      screws: group(spots.map((p) => own(translate(turned, p)) as Shape)),
      clear: spots.map((p) => hole(p, SCREW[size].clearance, -grip - 1, 1)),
      tap: spots.map((p) => hole(p, SCREW[size].tapDrill, -length - 2, 1 - grip)),
    };
  };
};
// A cable: a circle swept along a smooth curve through the points.
const cable = (points: P3[], r: number): Shape => {
  const [a, b] = points as [P3, P3];
  const start = own(unwrap(wire([own(circle(r, { at: a, axis: [b[0] - a[0], b[1] - a[1], b[2] - a[2]] }))])));
  const spine = own(unwrap(wire([own(unwrap(interpolateCurve(points)))])));
  return own(unwrap(sweep(start as never, spine, { mode: 'simple' }))) as Shape;
};
const pathLength = (points: P3[]): number =>
  points.slice(1).reduce((sum, p, i) => sum + Math.hypot(p[0] - (points[i] as P3)[0], p[1] - (points[i] as P3)[1], p[2] - (points[i] as P3)[2]), 0);

// ---- one wheel, with its axis on Z and its inner side at +Z. All six wheels are copies of it.
function wheelParts(bolted: Bolted) {
  const { radius: r, width: w, skin, grousers, grouserHeight } = WHEEL;
  const ring = (r0: number, r1: number, z0: number, z1: number): Shape =>
    solidOf(own(cylinder(r1, z1 - z0, { at: [0, 0, z0] })), [own(cylinder(r0, z1 - z0 + 2, { at: [0, 0, z0 - 1] }))]);
  // A chevron grouser is two bars that meet on the centre line of the tread.
  const skew = 9;
  const half = w / 2 / Math.cos(skew * DEG);
  const chevrons = Array.from({ length: grousers }, (_, i) =>
    [1, -1].map((side) => {
      const bar = own(translate(own(box(grouserHeight + 1, 6, half)), [r - 1, -3, side > 0 ? 0 : -half]));
      return own(rotate(own(rotate(bar, -side * skew, { axis: [1, 0, 0] })), (i * 360) / grousers)) as Shape;
    }),
  ).flat();
  const tyre = fused([
    ring(r - skin, r, -w / 2, w / 2),
    ring(r - 14, r, -w / 2, -w / 2 + 3),
    ring(r - 14, r, w / 2 - 3, w / 2),
    ring(r - 26, r, 60, 64),
    ring(r - 10, r, -70, -67),
    ...chevrons,
  ]);
  // Six flat spokes with a curve, from the hub to the stiffening ring inside the tread.
  const at = (x: number, y: number): P3 => [x, y, 30];
  const edges = [
    own(threePointArc(at(66, -2), at(150, 34), at(226, -2))),
    own(line(at(226, -2), at(226, 2))),
    own(threePointArc(at(226, 2), at(150, 38), at(66, 2))),
    own(line(at(66, 2), at(66, -2))),
  ];
  const spoke = own(unwrap(extrude(own(unwrap(face(own(unwrap(wire(edges))) as never))), 66))) as Shape;
  const spokes = Array.from({ length: 6 }, (_, i) => own(rotate(spoke, i * 60)) as Shape);
  // The drive actuator in the hub, with cooling ribs. A cap is bolted to its outer end, and the flange of the
  // suspension bracket to its inner end.
  const capRing = bolted([0, 0, -10], [0, 0, -1], 58, 8, 'M8', 30, 40);
  const flangeRing = bolted([0, 0, 275], [0, 0, 1], 58, 8, 'M6', 60, 70);
  const hub = solidOf(fused([own(cylinder(70, 195, { at: [0, 0, 20] })), ...[70, 110, 150, 190].map((z) => own(cylinder(80, 8, { at: [0, 0, z] })))]), [...capRing.tap, ...flangeRing.tap]);
  const cap = solidOf(own(cylinder(88, 30, { at: [0, 0, -10] })), capRing.clear);
  const flange = solidOf(own(cylinder(85, 60, { at: [0, 0, 215] })), flangeRing.clear);
  // The bracket beam goes through the flange: an access hole in the beam lets the top screw pass.
  const access = [58, -58].map((y) => own(cylinder(8, 80, { at: [0, y, 200] })) as Shape);
  return { tyre, spokes, hub, cap, capBolts: capRing.screws, flange, flangeBolts: flangeRing.screws, access };
}

// ---- the suspension pose. Each side is a planar linkage: the bogie keeps the middle and the rear wheel on the
// ground, and the rocker keeps the front wheel and the bogie pivot on their heights. The differential gives
// the body the mean of the two rocker angles.
const turn = (v: P2, a: number): P2 => [v[0] * Math.cos(a) - v[1] * Math.sin(a), v[0] * Math.sin(a) + v[1] * Math.cos(a)];
const solveAngle = (v: P2, rise: number): number => Math.asin(rise / Math.hypot(v[0], v[1])) - Math.atan2(v[1], v[0]);
function sidePose(frontGround: number) {
  const r = WHEEL.radius;
  const middle: P2 = [-BOGIE[0], r - BOGIE[1]];
  const rear: P2 = [AXLE.rear - BOGIE[0], r - BOGIE[1]];
  const bogie = solveAngle([middle[0] - rear[0], middle[1] - rear[1]], 0);
  const bogieZ = r - turn(middle, bogie)[1];
  const front: P2 = [AXLE.front - PIVOT[0], r - PIVOT[1]];
  const arm: P2 = [BOGIE[0] - PIVOT[0], BOGIE[1] - PIVOT[1]];
  const rocker = solveAngle([front[0] - arm[0], front[1] - arm[1]], frontGround + r - bogieZ);
  const pivotZ = frontGround + r - turn(front, rocker)[1];
  return { rocker, bogie, pivotZ, bogieAt: [PIVOT[0] + turn(arm, rocker)[0], bogieZ] as P2 };
}
// The pose of each link when the ground under the left front wheel is at the height lift.
function suspension(lift: number) {
  const left = sidePose(lift);
  const right = sidePose(0);
  return {
    left,
    right,
    pitch: (left.rocker + right.rocker) / 2,
    roll: Math.asin((left.pivotZ - right.pivotZ) / (2 * PIVOT_Y)),
    rise: (left.pivotZ + right.pivotZ) / 2 - PIVOT[1],
  };
}

// All parts of the rover on flat ground, each with its mass, for a reach of the arm.
function roverParts(arm = 0): Part[] {
  const parts: Part[] = [];
  const weigh = (shape: Shape): { volume: number; at: P3 } => {
    const props = unwrap(measureVolumeProps(shape));
    return { volume: props.volume, at: [...props.centerOfMass] as P3 };
  };
  // Parts whose mass is their volume times the density of their material.
  const add = (system: System, tone: Tone, link: Link, density: number, ...shapes: Shape[]): void => {
    for (const shape of shapes) {
      const { volume, at } = weigh(shape);
      parts.push({ system, tone, link, shape, kg: volume * density, at });
    }
  };
  // The same, for the parts that the cutaway opens.
  const skin = (system: System, tone: Tone, density: number, ...shapes: Shape[]): void => {
    for (const shape of shapes) {
      const { volume, at } = weigh(shape);
      parts.push({ system, tone, link: 'body', shape, kg: volume * density, at, skin: true });
    }
  };
  // A group of parts with one known mass, which the parts share by volume.
  const lump = (system: System, link: Link, kg: number, list: [Tone, Shape][]): void => {
    const weighed = list.map(([tone, shape]) => ({ tone, shape, ...weigh(shape) }));
    const total = weighed.reduce((sum, p) => sum + p.volume, 0);
    for (const p of weighed) parts.push({ system, tone: p.tone, link, shape: p.shape, kg: (kg * p.volume) / total, at: p.at });
  };
  // A cable harness. Its mass is its length times its section, and its centre is the mean of its points.
  const harness = (system: System, link: Link, r: number, points: P3[]): void => {
    const at = [0, 1, 2].map((k) => points.reduce((sum, p) => sum + (p[k] as number), 0) / points.length) as P3;
    parts.push({ system, tone: 'gold', link, shape: cable(points, r), kg: DENSITY.cable * Math.PI * r * r * pathLength(points), at });
  };
  const bolted = fasteners();
  // An actuator: a ribbed can from a to b, with a cap at b. Eight screws go through the cap into the can.
  // Actuators of one size and direction are copies.
  const actuators = new Map<string, { a: P3; shapes: Shape[] }>();
  const actuator = (system: System, link: Link, a: P3, b: P3, r: number): void => {
    const len = Math.hypot(b[0] - a[0], b[1] - a[1], b[2] - a[2]);
    const n: P3 = [(b[0] - a[0]) / len, (b[1] - a[1]) / len, (b[2] - a[2]) / len];
    const key = [r, len, ...n].join(' ');
    if (!actuators.has(key)) {
      const out = (d: number): P3 => along(a, b, 1 + d / len);
      const ring = bolted(out(12), n, r - 8, 8, 'M6', 12, 20);
      const can = solidOf(fused([rod(a, b, r), ...[0.25, 0.5, 0.75].map((t) => rod(along(a, b, t - 4 / len), along(a, b, t + 4 / len), r + 7))]), ring.tap);
      actuators.set(key, { a, shapes: [can, solidOf(rod(b, out(12), r + 6), ring.clear), ring.screws] });
    }
    const first = actuators.get(key) as { a: P3; shapes: Shape[] };
    const [can, cap, screws] = first.shapes.map((s) => own(translate(s, [a[0] - first.a[0], a[1] - first.a[1], a[2] - first.a[2]])) as Shape) as [Shape, Shape, Shape];
    add(system, 'dark', link, DENSITY.aluminium, can);
    add(system, 'metal', link, DENSITY.aluminium, cap, screws);
  };

  // ---- wheels and suspension, one side at a time (side = 1 is the left)
  const wheel = wheelParts(bolted);
  const r = WHEEL.radius;
  for (const side of [1, -1] as const) {
    const rocker: Link = side > 0 ? 'rockerL' : 'rockerR';
    const bogie: Link = side > 0 ? 'bogieL' : 'bogieR';
    const corner = (side * AXLE.cornerTrack) / 2;
    const middle = (side * AXLE.middleTrack) / 2;
    const placeWheel = (link: Link, x: number, y: number): void => {
      const put = (s: Shape): Shape => own(translate(own(rotate(s, side * 90, { axis: [1, 0, 0] })), [x, y, r])) as Shape;
      add('wheels', 'dark', link, DENSITY.aluminium, put(wheel.tyre), put(wheel.hub));
      add('wheels', 'titanium', link, DENSITY.titanium, ...wheel.spokes.map(put));
      add('wheels', 'metal', link, DENSITY.aluminium, put(wheel.cap), put(wheel.capBolts));
      // The bracket from the inner end of the hub up to the suspension.
      const inner = y - side * 245;
      add('suspension', 'titanium', link, DENSITY.titanium, solidOf(beam([x, inner, r], [x, inner, 540], 70, 50, 3), wheel.access.map(put)), put(wheel.flange));
      add('suspension', 'metal', link, DENSITY.aluminium, put(wheel.flangeBolts));
    };
    // A corner wheel hangs from a steering actuator above the tread.
    const steered = (link: Link, x: number): void => {
      placeWheel(link, x, corner);
      const inner = corner - side * 245;
      add('suspension', 'titanium', link, DENSITY.titanium, beam([x, inner - side * 25, 565], [x, corner, 565], 70, 50, 3));
      actuator('suspension', link, [x, corner, 590], [x, corner, 730], 52);
      add('suspension', 'dark', link, DENSITY.aluminium, rod([x, corner - side * 50, 690], [x, corner - side * 150, 690], 30));
    };
    steered(rocker, AXLE.front);
    steered(bogie, AXLE.rear);
    placeWheel(bogie, 0, middle);

    const pivot: P3 = [PIVOT[0], side * PIVOT_Y, PIVOT[1]];
    const bogiePivot: P3 = [BOGIE[0], side * BOGIE_Y, BOGIE[1]];
    const frontEnd: P3 = [AXLE.front - 50, corner, 665];
    const rearEnd: P3 = [AXLE.rear + 50, corner, 665];
    const middleEnd: P3 = [0, middle - side * 245, 540];
    add('suspension', 'titanium', rocker, DENSITY.titanium, rod(along(pivot, frontEnd, 0.075), frontEnd, 45, 42), rod(along(pivot, bogiePivot, 0.09), bogiePivot, 45, 42));
    add('suspension', 'titanium', bogie, DENSITY.titanium, rod(along(bogiePivot, middleEnd, 0.12), middleEnd, 40, 37), rod(along(bogiePivot, rearEnd, 0.1), rearEnd, 40, 37));
    // The pivot housings. Ten screws go through the cap on the outer side into the housing.
    const knuckle = (link: Link, c: P3, radius: number, y0: number, y1: number): void => {
      const ring = bolted([c[0], c[1] + side * (y1 + 10), c[2]], [0, side, 0], radius - 22, 10, 'M5', 10, 20);
      add('suspension', 'titanium', link, DENSITY.titanium, solidOf(rod([c[0], c[1] + side * y0, c[2]], [c[0], c[1] + side * y1, c[2]], radius), ring.tap));
      add('suspension', 'metal', link, DENSITY.aluminium, solidOf(rod([c[0], c[1] + side * y1, c[2]], [c[0], c[1] + side * (y1 + 10), c[2]], radius - 12), ring.clear), ring.screws);
    };
    knuckle(rocker, pivot, 72, -55, 55);
    knuckle(bogie, bogiePivot, 62, 50, 115);
    // The harness to each wheel runs along the tubes.
    harness('suspension', rocker, 9, [along(pivot, frontEnd, 0.06, 60), along(pivot, frontEnd, 0.5, 58), along(pivot, frontEnd, 0.93, 62), [AXLE.front - 20, corner - side * 30, 748]]);
    harness('suspension', rocker, 9, [along(pivot, bogiePivot, 0.08, 60), along(pivot, bogiePivot, 0.5, 58), along(pivot, bogiePivot, 0.9, 62)]);
    harness('suspension', bogie, 8, [along(bogiePivot, rearEnd, 0.1, 54), along(bogiePivot, rearEnd, 0.5, 52), along(bogiePivot, rearEnd, 0.92, 56), [AXLE.rear + 20, corner - side * 30, 748]]);
    harness('suspension', bogie, 8, [along(bogiePivot, middleEnd, 0.1, 54), along(bogiePivot, middleEnd, 0.55, 52), along(bogiePivot, middleEnd, 0.95, 50), [0, middle - side * 245, 430]]);
    // The body side: the axle of the rocker and the link up to the differential bar.
    add('suspension', 'titanium', 'body', DENSITY.titanium, rod([PIVOT[0], side * BODY.half, PIVOT[1]], [PIVOT[0], side * (PIVOT_Y - 55), PIVOT[1]], 40));
    add('suspension', 'titanium', 'body', DENSITY.titanium, rod([PIVOT[0] - 150, side * (BODY.half + 55), PIVOT[1] + 40], [PIVOT[0] - 150, side * (BODY.half + 55), DECK + 60], 14));
    add('suspension', 'metal', 'body', DENSITY.aluminium, rod([PIVOT[0] - 150, side * (BODY.half + 40), DECK + 60], [PIVOT[0] - 150, side * (BODY.half + 70), DECK + 60], 24));
  }
  // The differential bar. Eight screws go through the pivot cap into the top wall of the bar.
  const pivotRing = bolted([PIVOT[0] - 150, 0, DECK + 90], [0, 0, 1], 22, 8, 'M6', 12, 16);
  add('suspension', 'titanium', 'body', DENSITY.titanium, solidOf(beam([PIVOT[0] - 150, -BODY.half - 60, DECK + 60], [PIVOT[0] - 150, BODY.half + 60, DECK + 60], 60, 36, 3), pivotRing.tap));
  add('suspension', 'dark', 'body', DENSITY.aluminium, own(cylinder(70, 44, { at: [PIVOT[0] - 150, 0, DECK] })));
  add('suspension', 'metal', 'body', DENSITY.aluminium, solidOf(own(cylinder(48, 12, { at: [PIVOT[0] - 150, 0, DECK + 78] })), pivotRing.clear), pivotRing.screws);

  // ---- body: a thin aluminium box with sloped ends below, a deck plate, side panels and a rail round the deck
  const { x0, x1, half } = BODY;
  const wedge = (x: number, dir: 1 | -1, grow: number): Shape =>
    own(unwrap(extrude(own(unwrap(polygon([[x, -half - 1, CLEARANCE - 1], [x - dir * (260 + grow), -half - 1, CLEARANCE - 1], [x, -half - 1, CLEARANCE + 150 + grow * 0.58]]))), [0, 2 * half + 2, 0]))) as Shape;
  // The body shape, smaller by an inset on each side. The shell is the shape less its 3 mm inset.
  const hull = (inset: number): Shape =>
    solidOf(rounded(block(x0 + inset, x1 - inset, -half + inset, half - inset, CLEARANCE + inset, DECK - inset), 45 - inset), [wedge(x1 + 1, 1, 2 * inset), wedge(x0 - 1, -1, 2 * inset)]);
  skin('body', 'white', DENSITY.aluminium, solidOf(hull(0), [hull(3)]));
  skin('body', 'white', DENSITY.aluminium, rounded(block(x0 - 30, x1 + 30, -half - 30, half + 30, DECK, DECK + 6), 60));
  for (const s of [-1, 1]) {
    const [y0, y1] = s > 0 ? [half, half + 5] : [-half - 5, -half];
    skin('body', 'white', DENSITY.aluminium, block(x0 + 140, PIVOT[0] - 260, y0, y1, 730, 1050), block(PIVOT[0] + 160, x1 - 150, y0, y1, 730, 1050));
    skin('body', 'gold', DENSITY.instrument, block(x0 + 50, x0 + 120, y0, y1, 700, 1070));
    skin('body', 'metal', DENSITY.aluminium, rod([x0 + 20, s * (half + 14), DECK + 22], [x1 - 20, s * (half + 14), DECK + 22], 7));
    skin('body', 'metal', DENSITY.aluminium, group([-640, -280, 0, 380, 700].map((x) => rod([x, s * (half + 14), DECK + 6], [x, s * (half + 14), DECK + 22], 5))));
  }
  for (const x of [x0 - 14, x1 + 14]) add('body', 'metal', 'body', DENSITY.aluminium, rod([x, -half + 30, DECK + 22], [x, half - 30, DECK + 22], 7));

  // ---- deck: instrument covers with inlets, a calibration target, lift fittings, markers and a cable tray
  skin('body', 'white', DENSITY.instrument, rounded(block(150, 520, 190, 600, DECK + 6, DECK + 70), 30));
  for (const [x, y] of [[240, 290], [240, 480], [430, 290]] as P2[]) {
    skin('body', 'metal', DENSITY.aluminium, rod([x, y, DECK + 70], [x, y, DECK + 86], 42, 30));
    skin('body', 'white', DENSITY.aluminium, rod([x + 62, y, DECK + 86], [x + 62, y, DECK + 92], 44));
  }
  add('body', 'white', 'body', DENSITY.instrument, rounded(block(-420, -120, -560, -240, DECK + 6, DECK + 46), 30), rounded(block(330, 560, -330, -80, DECK + 6, DECK + 36), 20), rounded(block(-660, -480, -160, 120, DECK + 6, DECK + 90), 20));
  add('body', 'metal', 'body', DENSITY.aluminium, rod([-270, -400, DECK + 46], [-270, -400, DECK + 56], 74), rod([-270, -400, DECK + 56], [-270, -400, DECK + 96], 5));
  add('body', 'accent', 'body', DENSITY.instrument, group([0, 1, 2, 3].map((i) => own(cylinder(15, 4, { at: [-270 + 46 * Math.cos(i * 90 * DEG + 0.8), -400 + 46 * Math.sin(i * 90 * DEG + 0.8), DECK + 56] })))));
  add('body', 'metal', 'body', DENSITY.aluminium, ...([[-560, -620], [700, 60], [-600, 60]] as P2[]).map(([x, y]) => own(cone(46, 24, 60, { at: [x, y, DECK + 6] }))));
  add('body', 'dark', 'body', DENSITY.instrument, group(([[-680, -700], [-200, -760], [300, -760], [760, -300], [760, 100], [-700, -300], [-100, -40], [600, -560]] as P2[]).map(([x, y]) => own(cylinder(15, 3, { at: [x, y, DECK + 6] })))));
  add('body', 'titanium', 'body', DENSITY.titanium, rod([x0 + 40, -half + 70, DECK + 18], [x1 - 260, -half + 70, DECK + 18], 10), rod([x0 + 40, -half + 96, DECK + 18], [x1 - 260, -half + 96, DECK + 18], 10));
  add('body', 'metal', 'body', DENSITY.aluminium, group([-600, -360, -120, 120, 360].map((x) => block(x - 12, x + 12, -half + 54, -half + 112, DECK + 6, DECK + 34))));
  // Hazard cameras in pairs, at the front and at the rear.
  for (const [x, dir] of [[x1, 1], [x0, -1]] as const)
    for (const y of [-330, -230, 230, 330]) {
      add('body', 'dark', 'body', DENSITY.instrument, block(Math.min(x, x + dir * 44), Math.max(x, x + dir * 44), y - 36, y + 36, 850, 920));
      add('body', 'metal', 'body', DENSITY.aluminium, rod([x + dir * 44, y, 885], [x + dir * 56, y, 885], 22, 14));
    }

  // ---- power source at the rear: a finned cylinder with its published mass, between two heat exchanger plates.
  // Twelve screws go through its end plate into the cylinder.
  const fin = Array.from({ length: 8 }, (_, i) => own(rotate(own(translate(own(box(200, 5, 600)), [120, -2.5, 30])), i * 45 + 22.5)) as Shape);
  const endRing = bolted([0, 0, 672], [0, 0, 1], 120, 12, 'M8', 24, 35);
  const generator = solidOf(fused([own(cylinder(130, 648)), own(cylinder(150, 24, { at: [0, 0, -12] })), ...fin]), endRing.tap);
  const endPlate = solidOf(own(cylinder(150, 24, { at: [0, 0, 648] })), endRing.clear);
  const lean = (s: Shape): Shape => own(translate(own(rotate(s, -65, { axis: [0, 1, 0] })), [x0 - 60, 0, 1010])) as Shape;
  // A point of the leaned frame: x across the cylinder, y to the left, z along the cylinder.
  const leanAt = (p: P3): P3 => [x0 - 60 + p[0] * Math.cos(65 * DEG) - p[2] * Math.sin(65 * DEG), p[1], 1010 + p[0] * Math.sin(65 * DEG) + p[2] * Math.cos(65 * DEG)];
  lump('power', 'body', PUBLISHED_KG.power, [['white', lean(generator)], ['white', lean(endPlate)], ['metal', lean(endRing.screws)]]);
  add('body', 'white', 'body', DENSITY.aluminium, ...[-1, 1].map((s) => lean(own(translate(own(box(520, 8, 620)), [-260, s * 400 - 4, 20])) as Shape)));
  add('body', 'titanium', 'body', DENSITY.titanium, ...[-1, 1].flatMap((s) => [rod([x0, s * 150, 980], leanAt([0, s * 110, 120]), 16), rod([x0, s * 420, 1040], leanAt([0, s * 400, 200]), 12), rod([x0, s * 150, 800], leanAt([-100, s * 100, 60]), 14)]));
  // Coolant tubes from the body to the heat exchanger plates.
  for (const s of [-1, 1]) {
    harness('body', 'body', 11, [[x0, s * 300, 1060], [x0 - 70, s * 330, 1085], leanAt([60, s * 386, 150]), leanAt([60, s * 386, 420])]);
    harness('body', 'body', 11, [[x0, s * 340, 1020], [x0 - 60, s * 370, 1040], leanAt([-60, s * 386, 120]), leanAt([-60, s * 386, 400])]);
  }

  // ---- mast with the camera head. The top of the head is 2.2 m above the ground.
  const [mx, my] = [700, -620];
  add('mast', 'white', 'body', DENSITY.aluminium, rod([mx, my, DECK + 96], [mx, my, 1822], 45, 41), rod([mx, my, DECK + 6], [mx, my, DECK + 26], 95));
  actuator('mast', 'body', [mx, my, DECK + 26], [mx, my, DECK + 96], 70);
  actuator('mast', 'body', [mx, my + 80, 1880], [mx, my - 80, 1880], 58);
  add('mast', 'white', 'body', DENSITY.aluminium, block(mx - 40, mx + 40, my - 114, my - 100, 1840, 1960), block(mx - 40, mx + 40, my + 100, my + 114, 1840, 1960));
  add('mast', 'white', 'body', DENSITY.instrument, rounded(block(mx - 70, mx + 120, my - 250, my + 250, 1940, 2050), 24), rounded(block(mx - 150, mx + 110, my - 135, my + 135, 2050, MAST_TOP - 6), 30));
  add('mast', 'dark', 'body', DENSITY.instrument, ...[-210, -123, 123, 210].map((dy) => rod([mx + 120, my + dy, 1995], [mx + 150, my + dy, 1995], Math.abs(dy) > 200 ? 26 : 34)), rod([mx + 110, my, 2120], [mx + 150, my, 2120], 60));
  add('mast', 'metal', 'body', DENSITY.aluminium, rod([mx + 150, my, 2120], [mx + 156, my, 2120], 60, 46), group([-210, -123, 123, 210].map((dy) => rod([mx + 150, my + dy, 1995], [mx + 156, my + dy, 1995], Math.abs(dy) > 200 ? 26 : 34, Math.abs(dy) > 200 ? 16 : 22))));
  add('mast', 'white', 'body', DENSITY.aluminium, block(mx - 160, mx + 170, my - 150, my + 150, MAST_TOP - 6, MAST_TOP));
  // Two weather booms and the harness up the mast.
  add('mast', 'titanium', 'body', DENSITY.titanium, rod([mx + 40, my, 1500], [mx + 360, my + 140, 1520], 13), rod([mx, my + 40, 1560], [mx - 140, my + 330, 1580], 13));
  add('mast', 'metal', 'body', DENSITY.aluminium, rod([mx, my, 1480], [mx, my, 1600], 52, 45));
  harness('mast', 'body', 8, [[mx - 62, my + 30, DECK + 110], [mx - 60, my + 34, 1400], [mx - 62, my + 30, 1700], [mx - 58, my + 40, 1800]]);

  // ---- robot arm, folded across the front. Its links are 2.2 m long from the shoulder to the centre of the turret.
  const shoulder = SHOULDER;
  const elbow: P3 = [shoulder[0], shoulder[1] - 1000, shoulder[2]];
  const wrist: P3 = [elbow[0] + 130, elbow[1] + 800, elbow[2] + 60];
  const turret: P3 = [wrist[0] + (ARM_LENGTH - 1000 - 800 - 130), wrist[1], wrist[2]];
  const turnsWith = (from: number, joint: 1 | 2 | 3): void => parts.slice(from).forEach((p) => (p.joint = joint));
  const armFrom = parts.length;
  add('arm', 'white', 'body', DENSITY.aluminium, rounded(block(x1, x1 + 82, shoulder[1] - 90, shoulder[1] + 90, 800, 1000), 20));
  actuator('arm', 'body', [shoulder[0], shoulder[1], shoulder[2] - 100], [shoulder[0], shoulder[1], shoulder[2] + 100], 78);
  const upperFrom = parts.length;
  add('arm', 'titanium', 'body', DENSITY.titanium, rod(along(shoulder, elbow, 0.08), along(shoulder, elbow, 0.93), 55, 51));
  actuator('arm', 'body', [elbow[0] + 65, elbow[1], elbow[2] - 100], [elbow[0] + 65, elbow[1], elbow[2] + 140], 72);
  harness('arm', 'body', 9, [along(shoulder, elbow, 0.12, 66), along(shoulder, elbow, 0.4, 62), along(shoulder, elbow, 0.65, 62), along(shoulder, elbow, 0.9, 70)]);
  turnsWith(upperFrom, 1);
  const foreFrom = parts.length;
  const fore: P3 = [wrist[0], elbow[1], wrist[2]];
  add('arm', 'titanium', 'body', DENSITY.titanium, rod(along(fore, wrist, 0.09), along(fore, wrist, 0.92), 50, 46));
  actuator('arm', 'body', [wrist[0], wrist[1], wrist[2] - 90], [wrist[0], wrist[1], wrist[2] + 90], 66);
  harness('arm', 'body', 9, [along(fore, wrist, 0.1, 62), along(fore, wrist, 0.5, 58), along(fore, wrist, 0.9, 64)]);
  turnsWith(foreFrom, 2);
  const handFrom = parts.length;
  actuator('arm', 'body', [wrist[0] + 66, wrist[1], wrist[2]], [turret[0] - 126, wrist[1], wrist[2]], 62);
  // The published mass of the arm goes to its parts by their share of the mass by density.
  const armParts = parts.slice(armFrom);
  const byDensity = armParts.reduce((sum, p) => sum + p.kg, 0);
  for (const p of armParts) p.kg *= PUBLISHED_KG.arm / byDensity;
  // The turret: a drum with five tools around it, with its published mass.
  const [tx, ty, tz] = turret;
  const tool = (angle: number, shape: Shape): Shape => own(rotate(shape, angle, { axis: [1, 0, 0], at: turret })) as Shape;
  lump('arm', 'body', PUBLISHED_KG.turret, [
    ['metal', rod([tx - 108, ty, tz], [tx + 90, ty, tz], 150)],
    ['dark', tool(0, fused([rod([tx - 90, ty, tz + 215], [tx + 170, ty, tz + 215], 64), own(cone(64, 22, 60, { at: [tx + 170, ty, tz + 215], axis: [1, 0, 0] }))]))],
    ['metal', tool(0, group([rod([tx + 230, ty, tz + 215], [tx + 330, ty, tz + 215], 11), rod([tx + 150, ty - 84, tz + 215], [tx + 300, ty - 84, tz + 215], 9), rod([tx + 150, ty + 84, tz + 215], [tx + 300, ty + 84, tz + 215], 9)]))],
    ['white', tool(72, rounded(block(tx - 80, tx + 120, ty - 85, ty + 85, tz + 150, tz + 290), 22))],
    ['gold', tool(144, rod([tx + 110, ty, tz + 220], [tx + 150, ty, tz + 220], 62))],
    ['metal', tool(144, rod([tx - 60, ty, tz + 220], [tx + 110, ty, tz + 220], 56))],
    ['dark', tool(216, rod([tx - 70, ty, tz + 205], [tx + 130, ty, tz + 205], 50))],
    ['metal', tool(216, rod([tx + 130, ty, tz + 205], [tx + 138, ty, tz + 205], 50, 34))],
    ['white', tool(288, fused([rod([tx - 60, ty, tz + 215], [tx + 100, ty, tz + 215], 62), rod([tx + 100, ty, tz + 215], [tx + 116, ty, tz + 215], 74)]))],
  ]);

  turnsWith(handFrom, 3);
  // The pose of the arm: a part turns with its own joint, then with each joint before it.
  const joints = armJoints(Math.min(1, Math.max(0, arm)));
  for (const p of parts) {
    for (let j = p.joint ?? 0; j >= 1 && arm > 0; j--) {
      const [about, angle] = joints[j - 1] as [P2, number];
      p.shape = own(rotate(p.shape, angle, { at: [about[0], about[1], 0] })) as Shape;
      const moved = turn([p.at[0] - about[0], p.at[1] - about[1]], angle * DEG);
      p.at = [about[0] + moved[0], about[1] + moved[1], p.at[2]];
    }
  }

  // ---- antennas: a hexagonal high-gain dish on a gimbal, a helix can at the right rear, a low-gain cone
  const hexagon = own(unwrap(extrude(own(unwrap(polygon(Array.from({ length: 6 }, (_, i): P3 => [162 * Math.cos(i * 60 * DEG), 162 * Math.sin(i * 60 * DEG), 0])))), 30))) as Shape;
  add('antennas', 'gold', 'body', DENSITY.instrument, own(translate(own(rotate(hexagon, 35, { axis: [0, 1, 0] })), [-640, 640, 1420])) as Shape);
  add('antennas', 'white', 'body', DENSITY.aluminium, rod([-640, 640, DECK + 6], [-640, 640, 1350], 22, 19), rod([-640, 590, 1385], [-640, 690, 1385], 34), block(-668, -612, 690, 702, 1340, 1430), block(-668, -612, 578, 590, 1340, 1430));
  add('antennas', 'white', 'body', DENSITY.aluminium, rod([-610, -650, DECK + 6], [-610, -650, 1260], 22, 19), own(cone(40, 22, 40, { at: [-610, -650, 1260] })));
  add('antennas', 'white', 'body', DENSITY.instrument, rod([-610, -650, 1300], [-610, -650, 1560], 56));
  const coil = own(unwrap(sweep(own(unwrap(wire([own(circle(5, { at: [62, 0, 0], axis: [0, 1, 0.13] }))]))) as never, own(helix(52, 250, 62)), { mode: 'simple' }))) as Shape;
  add('antennas', 'gold', 'body', DENSITY.cable, own(translate(coil, [-610, -650, 1305])) as Shape);
  add('antennas', 'white', 'body', DENSITY.aluminium, rod([-660, 420, DECK + 6], [-660, 420, 1230], 14), own(cone(34, 14, 90, { at: [-660, 420, 1230] })));

  // ---- equipment inside the body: laboratory instruments under the inlets, batteries, avionics and a pump.
  // It has the mass that the other parts leave, and the heavy boxes sit toward the rear to balance the arm.
  const z0 = CLEARANCE + 36;
  const top = DECK - 3; // the two laboratory instruments hang from the deck, under their inlets
  for (const [x, y] of [[240, 290], [240, 480], [430, 290]] as P2[]) add('equipment', 'metal', 'body', DENSITY.aluminium, rod([x, y, top - 20], [x, y, top], 24, 20));
  harness('equipment', 'body', 12, [[-360, 690, z0 + 60], [100, 730, z0 + 90], [640, 690, z0 + 60], [770, 300, z0 + 80], [760, -200, z0 + 60]]);
  harness('equipment', 'body', 12, [[-360, 690, z0 + 120], [-660, 690, z0 + 150], [-690, 100, z0 + 260], [-680, -500, z0 + 150]]);
  harness('equipment', 'body', 14, [[-530, 410, z0 + 260], [-420, 300, z0 + 340], [-200, 120, z0 + 260], [-160, -30, z0 + 200]]);
  harness('equipment', 'body', 14, [[335, 385, top - 350], [330, 200, top - 380], [260, 0, z0 + 260], [200, -150, z0 + 150]]);
  lump('equipment', 'body', TOTAL_KG - parts.reduce((sum, p) => sum + p.kg, 0), [
    ['gold', rounded(block(170, 500, 200, 570, top - 300, top - 20), 24)],
    ['metal', rod([335, 385, top - 350], [335, 385, top - 300], 120)],
    ['white', rounded(block(-330, 40, 300, 660, top - 280, top - 20), 24)],
    ['dark', rounded(block(-670, -390, 160, 660, z0 + 100, z0 + 340), 20)],
    ['dark', rounded(block(-670, -390, -660, -160, z0 + 100, z0 + 340), 20)],
    ['white', rounded(block(-340, 180, -690, -330, z0, z0 + 340), 24)],
    ['white', rounded(block(420, 700, -660, -440, z0, z0 + 200), 24)],
    ['metal', rounded(block(-340, 20, -270, 200, z0, z0 + 200), 20)],
    ['metal', rod([200, -150, z0], [200, -150, z0 + 150], 85)],
    ['metal', rod([600, 60, z0], [600, 60, z0 + 120], 70)],
  ]);
  return parts;
}

// The cutaway takes one block out of the skin parts. A part that is all inside the block goes away.
function opened(parts: Part[]): Part[] {
  const opening = block(OPENING.x0, OPENING.x1, OPENING.y0, BODY.half + 60, OPENING.z0, DECK + 120);
  return parts.flatMap((p) => {
    if (!p.skin) return [p];
    const open = own(unwrap(cutAll(p.shape, [opening]))) as Shape;
    return getSolids(open).length === 0 ? [] : [{ ...p, shape: open }];
  });
}

interface RoverParams {
  lift?: number; // height of the ground under the left front wheel, 0 to 500 mm
  cutaway?: boolean; // open the deck and the left wall of the body
  arm?: number; // 0 = the arm folded across the front, 1 = straight out to its full reach
}

const rover = ({ lift = 0, cutaway = true, arm = 0 }: RoverParams = {}) => freeing(() => {
  const parts = roverParts(arm);
  const mass = parts.reduce((sum, p) => sum + p.kg, 0);
  const budget: Partial<Record<System, number>> = {};
  for (const p of parts) budget[p.system] = (budget[p.system] ?? 0) + p.kg;

  const shown = cutaway ? opened(parts) : parts;

  // Move each link to its pose. A link turns about a line along Y, the body also rolls about a line along X.
  const step = Math.min(500, Math.max(0, lift));
  const pose = suspension(step);
  // The same three moves work on a shape and on a point, so the centre of each part moves with its link.
  type Moves<T> = { tilt: (v: T, angle: number, about: P2) => T; roll: (v: T, angle: number) => T; shift: (v: T, by: P3) => T };
  const onShape: Moves<Shape> = {
    tilt: (s, angle, about) => own(rotate(s, -angle / DEG, { axis: [0, 1, 0], at: [about[0], 0, about[1]] })) as Shape,
    roll: (s, angle) => own(rotate(s, angle / DEG, { axis: [1, 0, 0], at: [0, 0, PIVOT[1]] })) as Shape,
    shift: (s, by) => own(translate(s, by)) as Shape,
  };
  const onPoint: Moves<P3> = {
    tilt: ([x, y, z], angle, about) => { const t = turn([x - about[0], z - about[1]], angle); return [about[0] + t[0], y, about[1] + t[1]]; },
    roll: ([x, y, z], angle) => { const t = turn([y, z - PIVOT[1]], angle); return [x, t[0], PIVOT[1] + t[1]]; },
    shift: ([x, y, z], by) => [x + by[0], y + by[1], z + by[2]],
  };
  const moved = <T,>(link: Link, v: T, m: Moves<T>): T => {
    if (step === 0) return v;
    if (link === 'body') return m.shift(m.roll(m.tilt(v, pose.pitch, PIVOT), pose.roll), [0, 0, pose.rise]);
    const side = link.endsWith('L') ? pose.left : pose.right;
    if (link.startsWith('rocker')) return m.shift(m.tilt(v, side.rocker, PIVOT), [0, 0, side.pivotZ - PIVOT[1]]);
    return m.shift(m.tilt(v, side.bogie, BOGIE), [side.bogieAt[0] - BOGIE[0], 0, side.bogieAt[1] - BOGIE[1]]);
  };
  const centre = [0, 1, 2].map((k) => parts.reduce((sum, p) => sum + p.kg * (moved(p.link, p.at, onPoint)[k] as number), 0) / mass) as P3;
  const tones: Tone[] = ['white', 'dark', 'titanium', 'metal', 'gold', 'accent'];
  const built = Object.fromEntries(
    tones.map((tone) => [tone, compound(shown.filter((p) => p.tone === tone).map((p) => moved(p.link, p.shape, onShape))) as Shape]),
  ) as Record<Tone, Shape>;
  // The ground is where the grousers touch it, a little below the tread circle.
  const dip = WHEEL.grouserHeight;
  const ground = compound([block(-1700, 1900, -1500, 1500, -40 - dip, -dip), ...(step > 0 ? [block(AXLE.front - 330, AXLE.front + 330, AXLE.cornerTrack / 2 - 260, AXLE.cornerTrack / 2 + 260, -dip, step - dip)] : [])]) as Shape;
  return { ...built, ground, mass, centre, budget };
});

// Show the rover. Try rover({ arm: 1 }) to reach out with the arm, rover({ lift: 400 }) to put the left front
// wheel on a step, or rover({ cutaway: false }).
const model = rover();
console.log(model.mass.toFixed(0), 'kg, centre of mass at', model.centre.map((v) => v.toFixed(0)).join(', '), 'mm');
export default [
  color(model.white, '#f2efe8'),
  color(model.dark, '#2b2f36'),
  color(model.titanium, '#9aa3ad'),
  color(model.metal, '#c9ccd1'),
  color(model.gold, '#c9a227'),
  color(model.accent, '#d8572a'),
  color(model.ground, '#b5653f'),
];
Functions used
box circle compound cone cutAll cylinder edgeFinder extrude face fillet fuseAll getSolids helix interpolateCurve line measureVolumeProps polygon rotate sweep threePointArc translate unwrap wire color